#2026
Scorpion v6
STM32PID controlLine follower
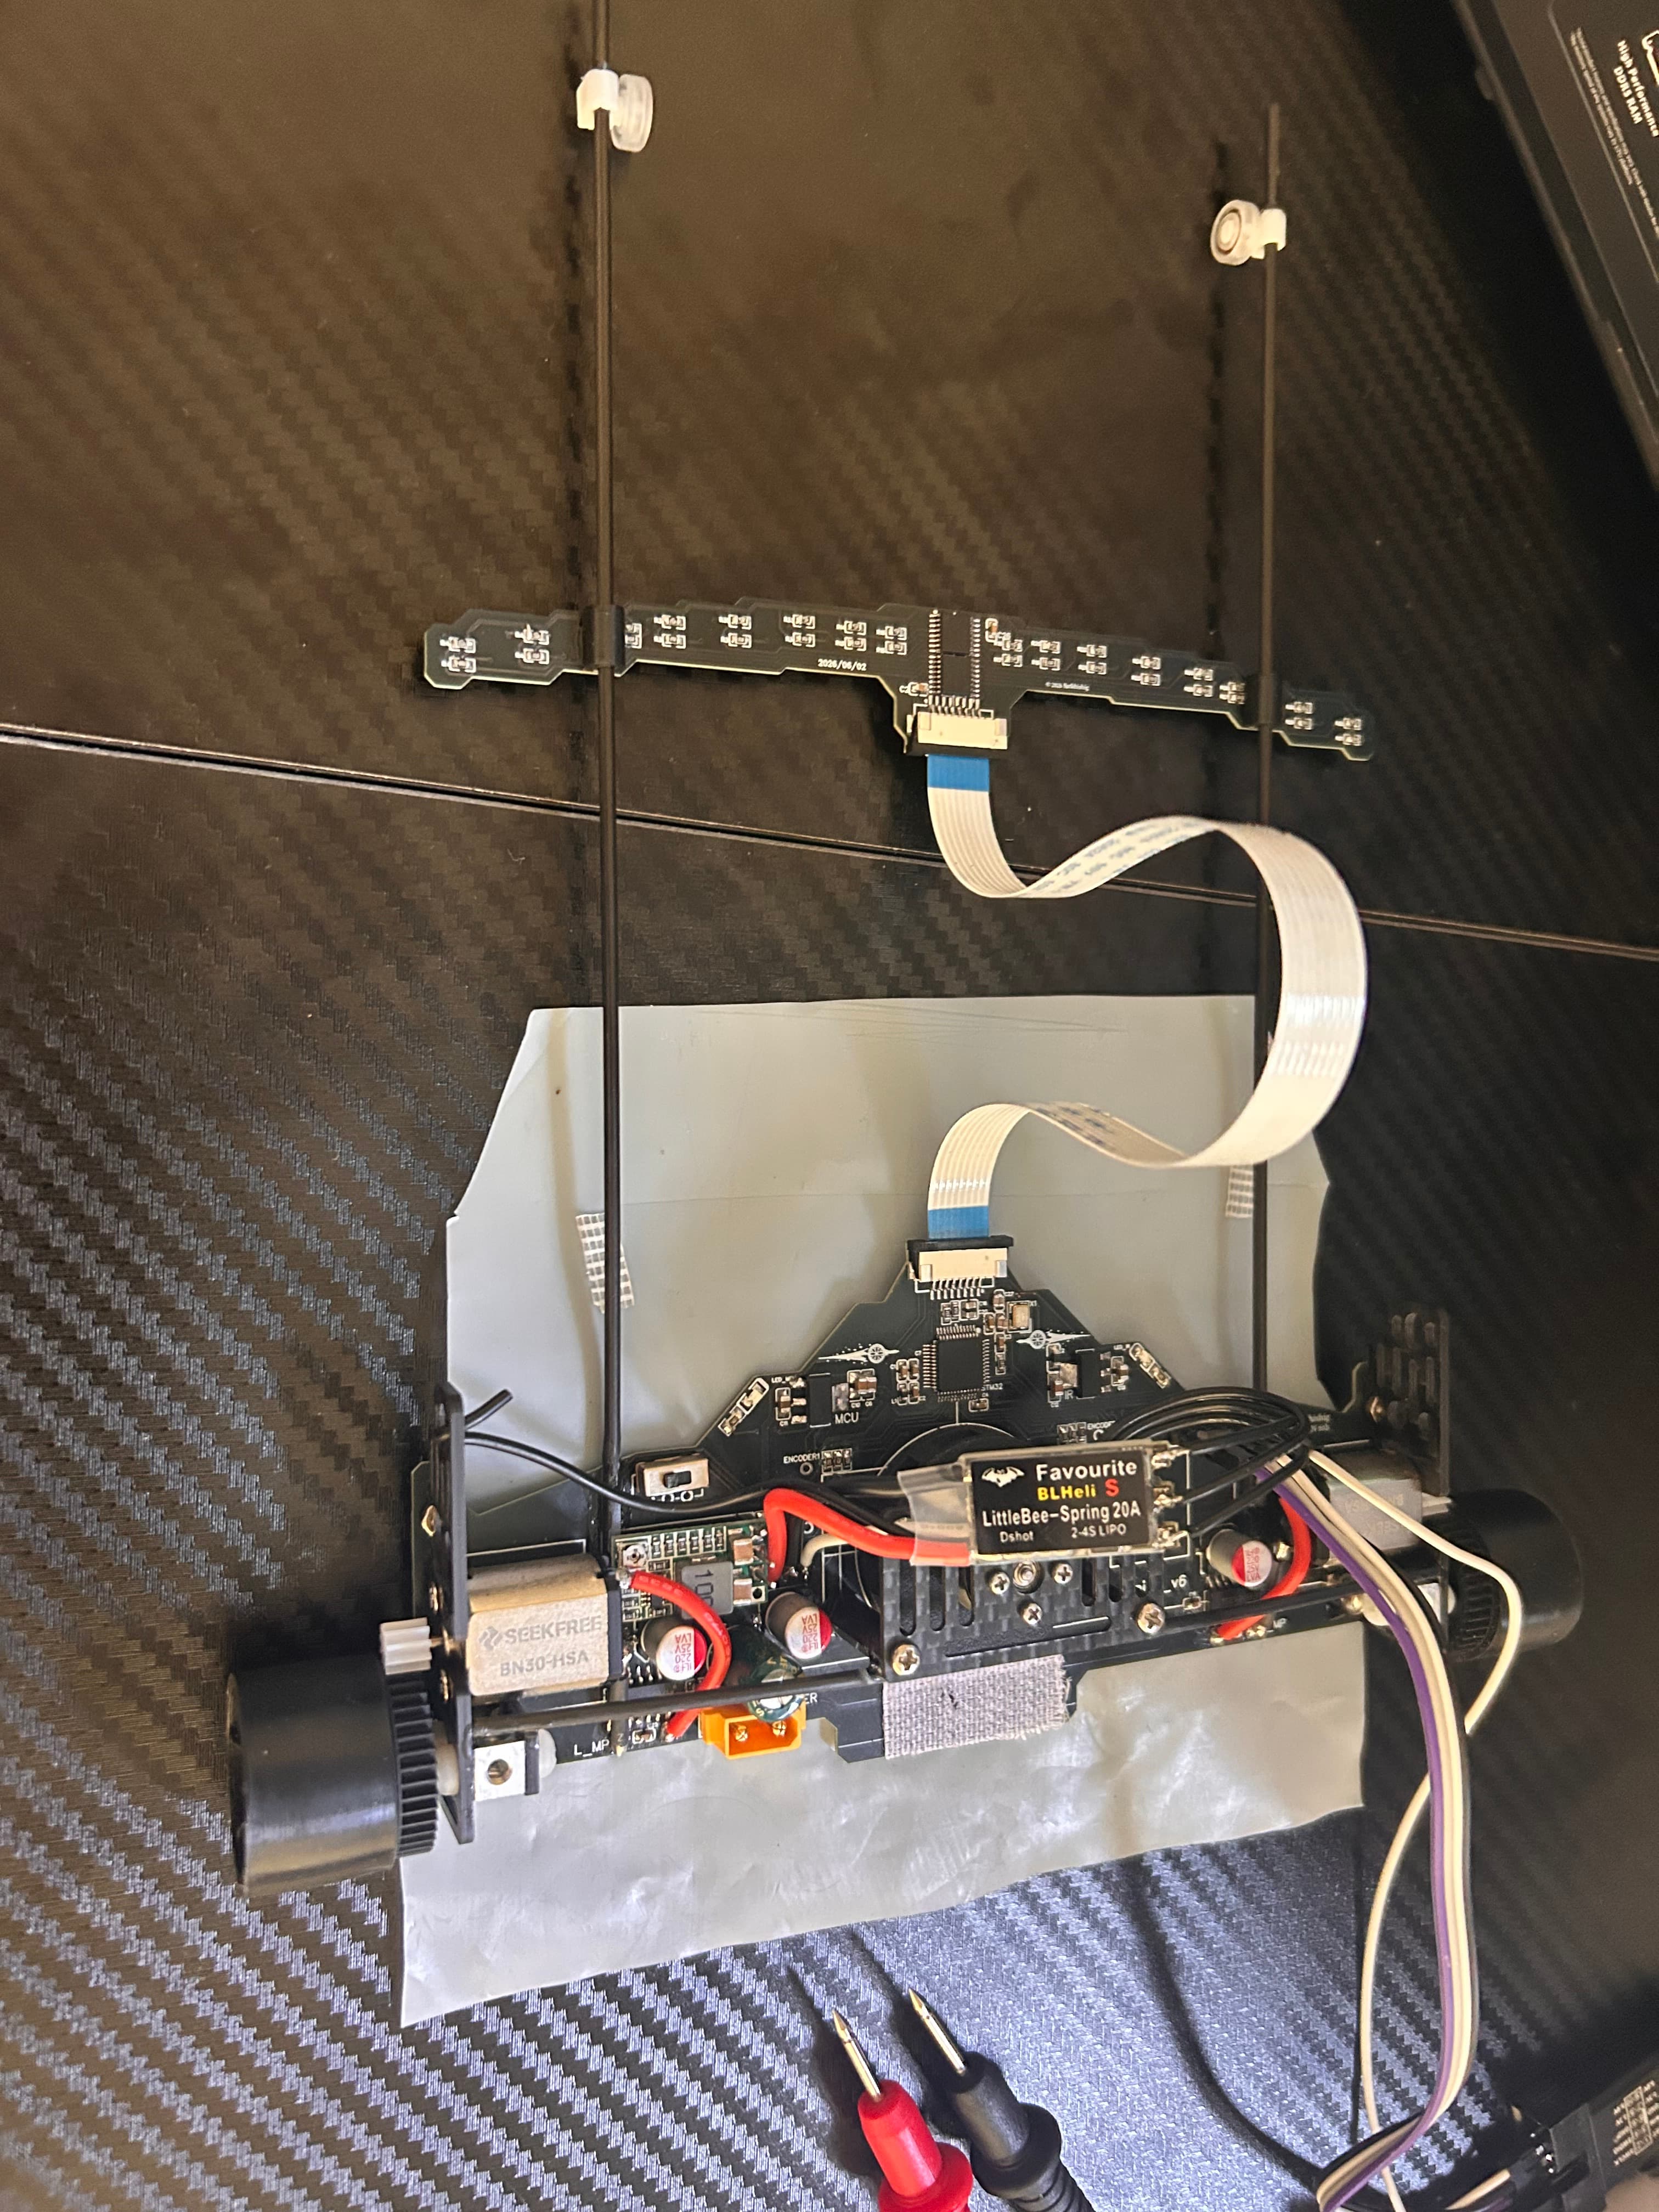
PID loop computing
4400Hz
Top speed
4.5M/s
Weight Class
120g
Main Compute
170Mhz
Power Delivery
34W
Control Loop
4.4KHz
Hardware Dissection
Interactive Robot Explorer
Tap any numbered hotspot to inspect subsystem specs, interface protocols, and design justifications.
BOM & Component Log
Bill of Materials Directory
MicrocontrollerQTY: 1
STM32F431CBT6
Part #:
Microcontroller with multiple interrupts and a high-speed ADC.
Brushless motorQTY: 1
1103 8500KV
Part #:
brushless motor for suction
DC motorQTY: 2
N30
Part #:
High-performance DC motor with a strong magnet
IR-sensorQTY: 1
IR-sensor array
Part #:
Custom-made IR sensor array consisting of 16 QRE1113.
Engineering Corps
View Full Team Roster arrow_forwardEngineered by MOGUL TEAM
Iterative R&D
Generational Development Timeline
Version 6 2026
first STM32 based scorpion
STM32-based scorpion with interrupt-driven closed-loop PID control.
MOGUL TEAM Fleet
View Entire Fleet arrow_forwardRelated Robots in the Arsenal
AUTONOMOUS
View Dossier chevron_rightApex MK-IV Autonomous SLAM Arena Bot
Full SLAM navigation arena rover with 2D LiDAR mapping and edge neural inferencing.
ARDUINO
View Dossier chevron_rightArduino Sensor Bench Testbed
Lab telemetry logger and optical encoder testing bench for onboarding recruits.
RC
View Dossier chevron_rightMogul Telemetry Scout Rover
Multi-terrain 6WD telemetry scout rover with pan-tilt FPV camera.
SUMO
View Dossier chevron_rightRazorback 500g Mini Sumo
Compact 500g autonomous ring fighter with ultra-sharp ground blades.